WalkBeside: Designing Navigational Delegation for a Semi-Autonomous Robot in Embodied Telepresence
Abstract
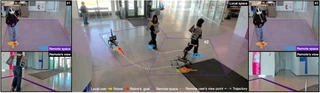
When a remote guest joins a local collaborator to explore an unfamiliar site, such as during infrastructure assessment or architectural walkthroughs, they must navigate an unseen environment while engaging in collaboration. Existing systems place the full burden of navigation on the remote user, fragmenting attention between driving the robot and participating in the task. We argue that this limitation arises not from insufficient autonomy, but from how navigational control is structured. We present WalkBeside, an interaction design in which the local collaborator leads, the robot follows by default, and the remote user continuously adjusts their position by simply moving within their physical room. This room-scale movement is mapped directly onto the robot’s position relative to the collaborator, allowing the remote user to step closer, shift to the side, or hold back as naturally as they would in person. Grounded in the “contesting control framework”, we design a mechanism which (1) surrenders navigation to the local collaborator by default, (2) maintains spatial awareness through an embodied view, and (3) expresses positional adjustment through implicit physical movement. We instantiate this through a VR-mediated quadruped telepresence system. WalkBeside enables remote users to participate as spatially engaged partners and full collaborators.
Publication
Under Review